Graduate Capstone Project @ SJSU Computer Engineering Department
This project implements a real-time control system for vehicle to realize autonomous driving in an unknown environment. The inspiration for this project is from an MIT course, entitled Robotics: Science and Systems.
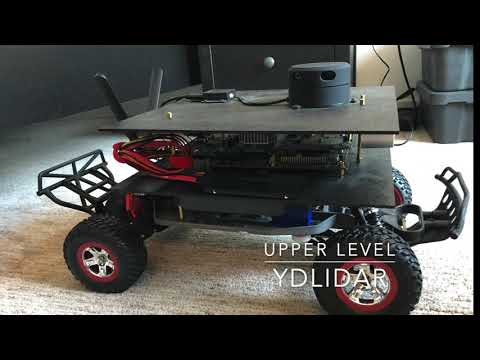
This project built a self-driving vehicle from a toy race car integrated with an on-board computer, which utilizes ZED 3D stereo camera and lidar to perform real-time autonomous driving in a building hallway. The ultimate goal is to build a race car to compete in the final competition meanwhile learning self-driving techniques.
The project starts with a single agent vehicle controlled by the Jetson TX2 embedded AI computer. Information gathered from the surrounding environment will be sent to the computer and cloud for processing. In the initial part of the project, the computation would be completed by the on-board computer, and later the computing part will be migrated to the cloud for multiple-agent processing.
Detailed implementation please see Medium post:
- Jetson TX2 Autonomous Vehicle System Configuration and Setup - I
- Jetson TX2 Autonomous Vehicle System Configuration and Setup - II
Detailed implementation please see Github repo:
Two and half minute showcase(click below picture):